Same brain, different bodies.
One agent, three robot arms, one dashboard.
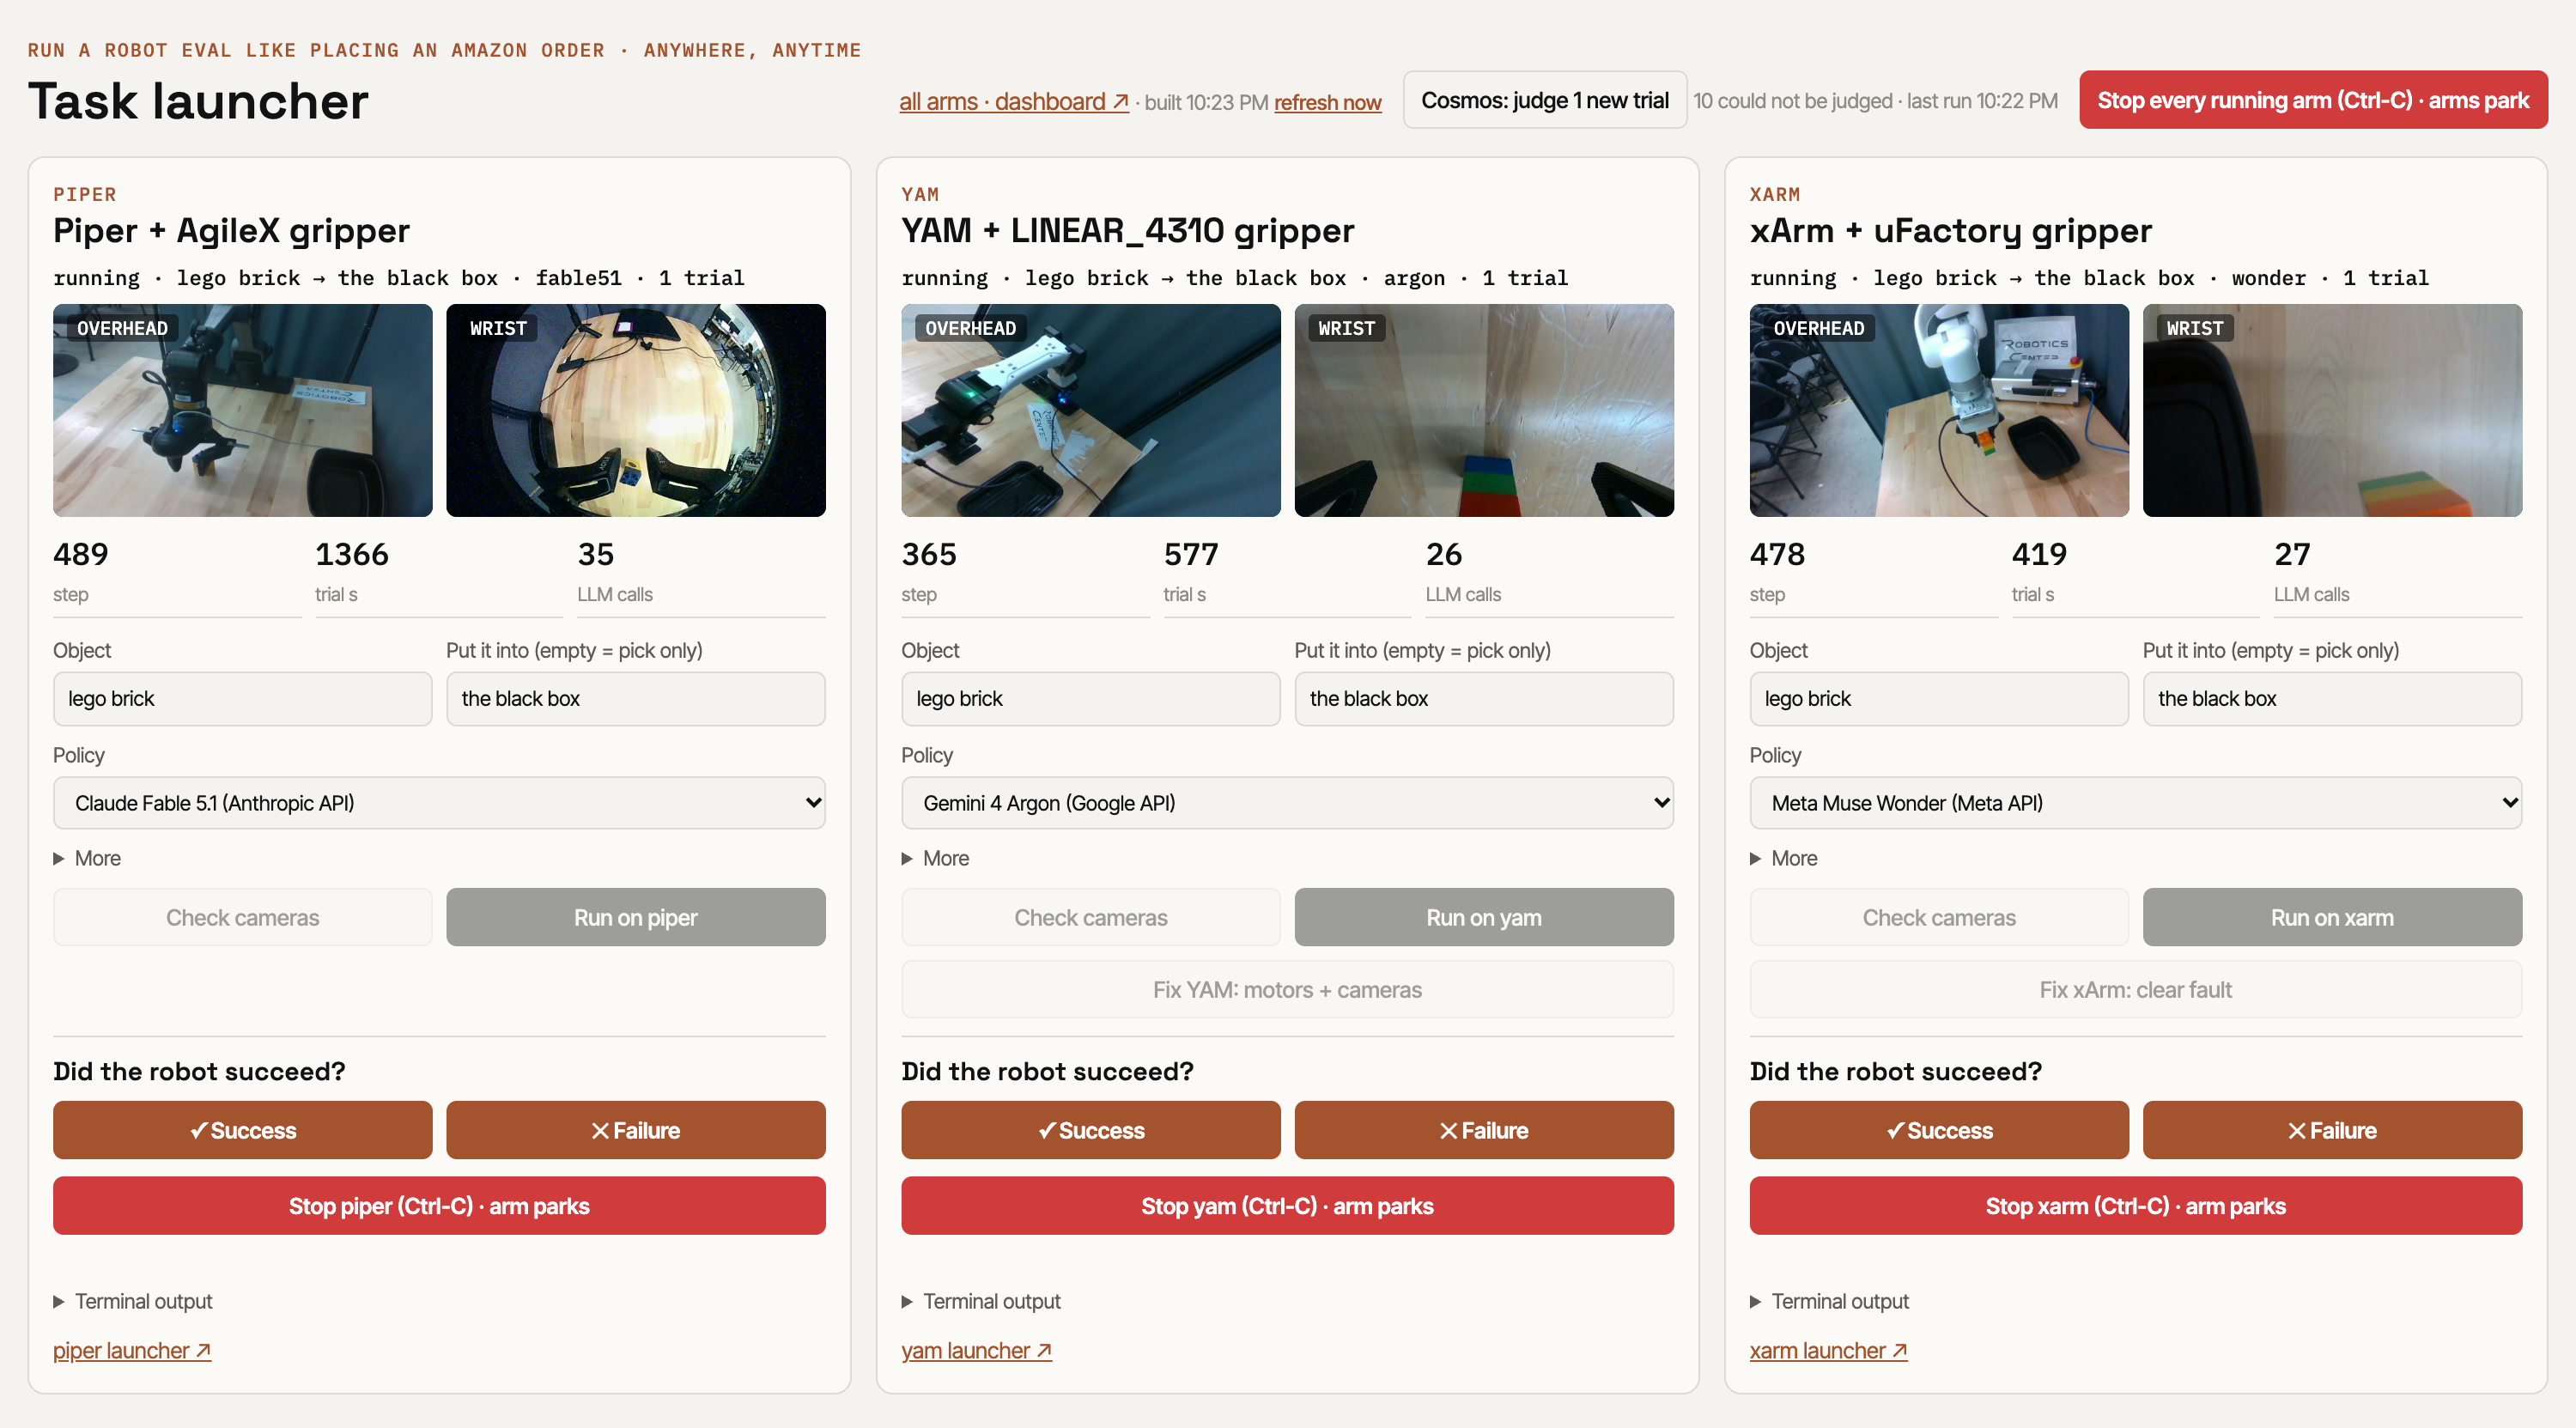
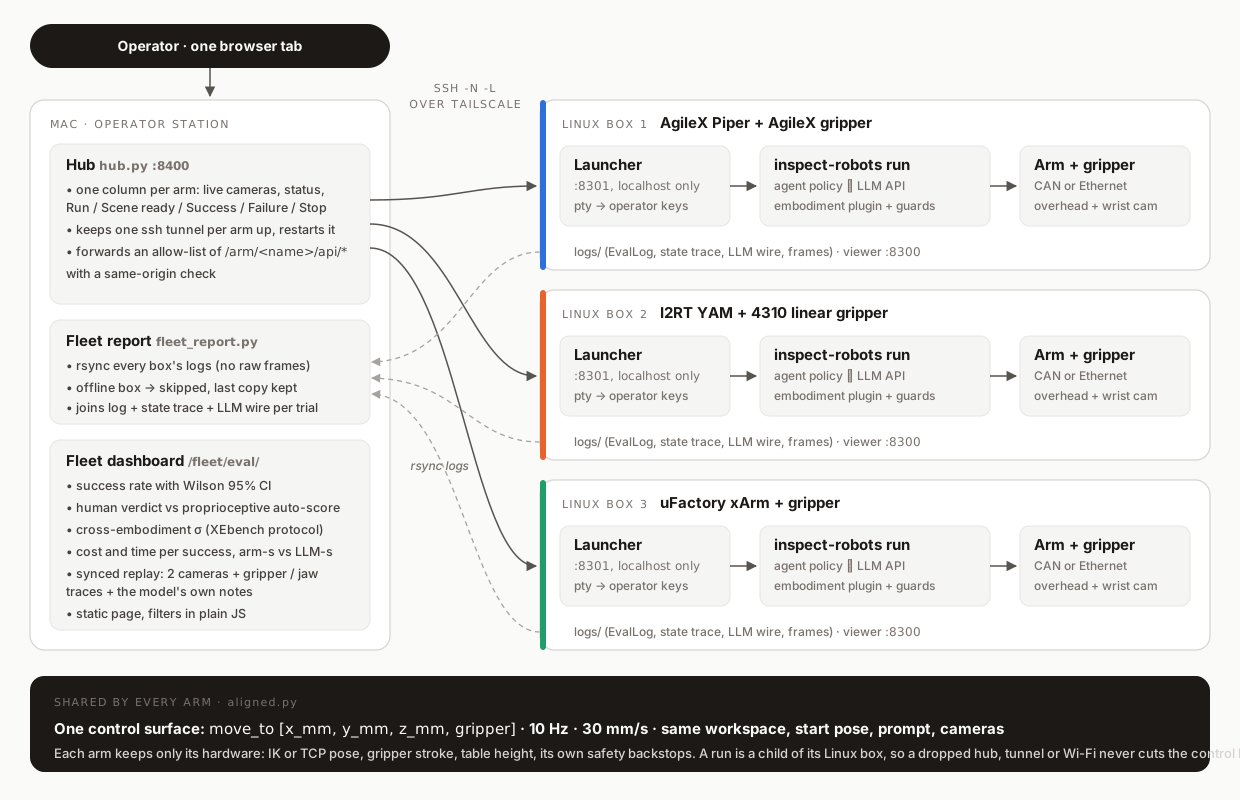
One hub, three arms running at once.
One column per arm: live cameras, progress, operator controls.
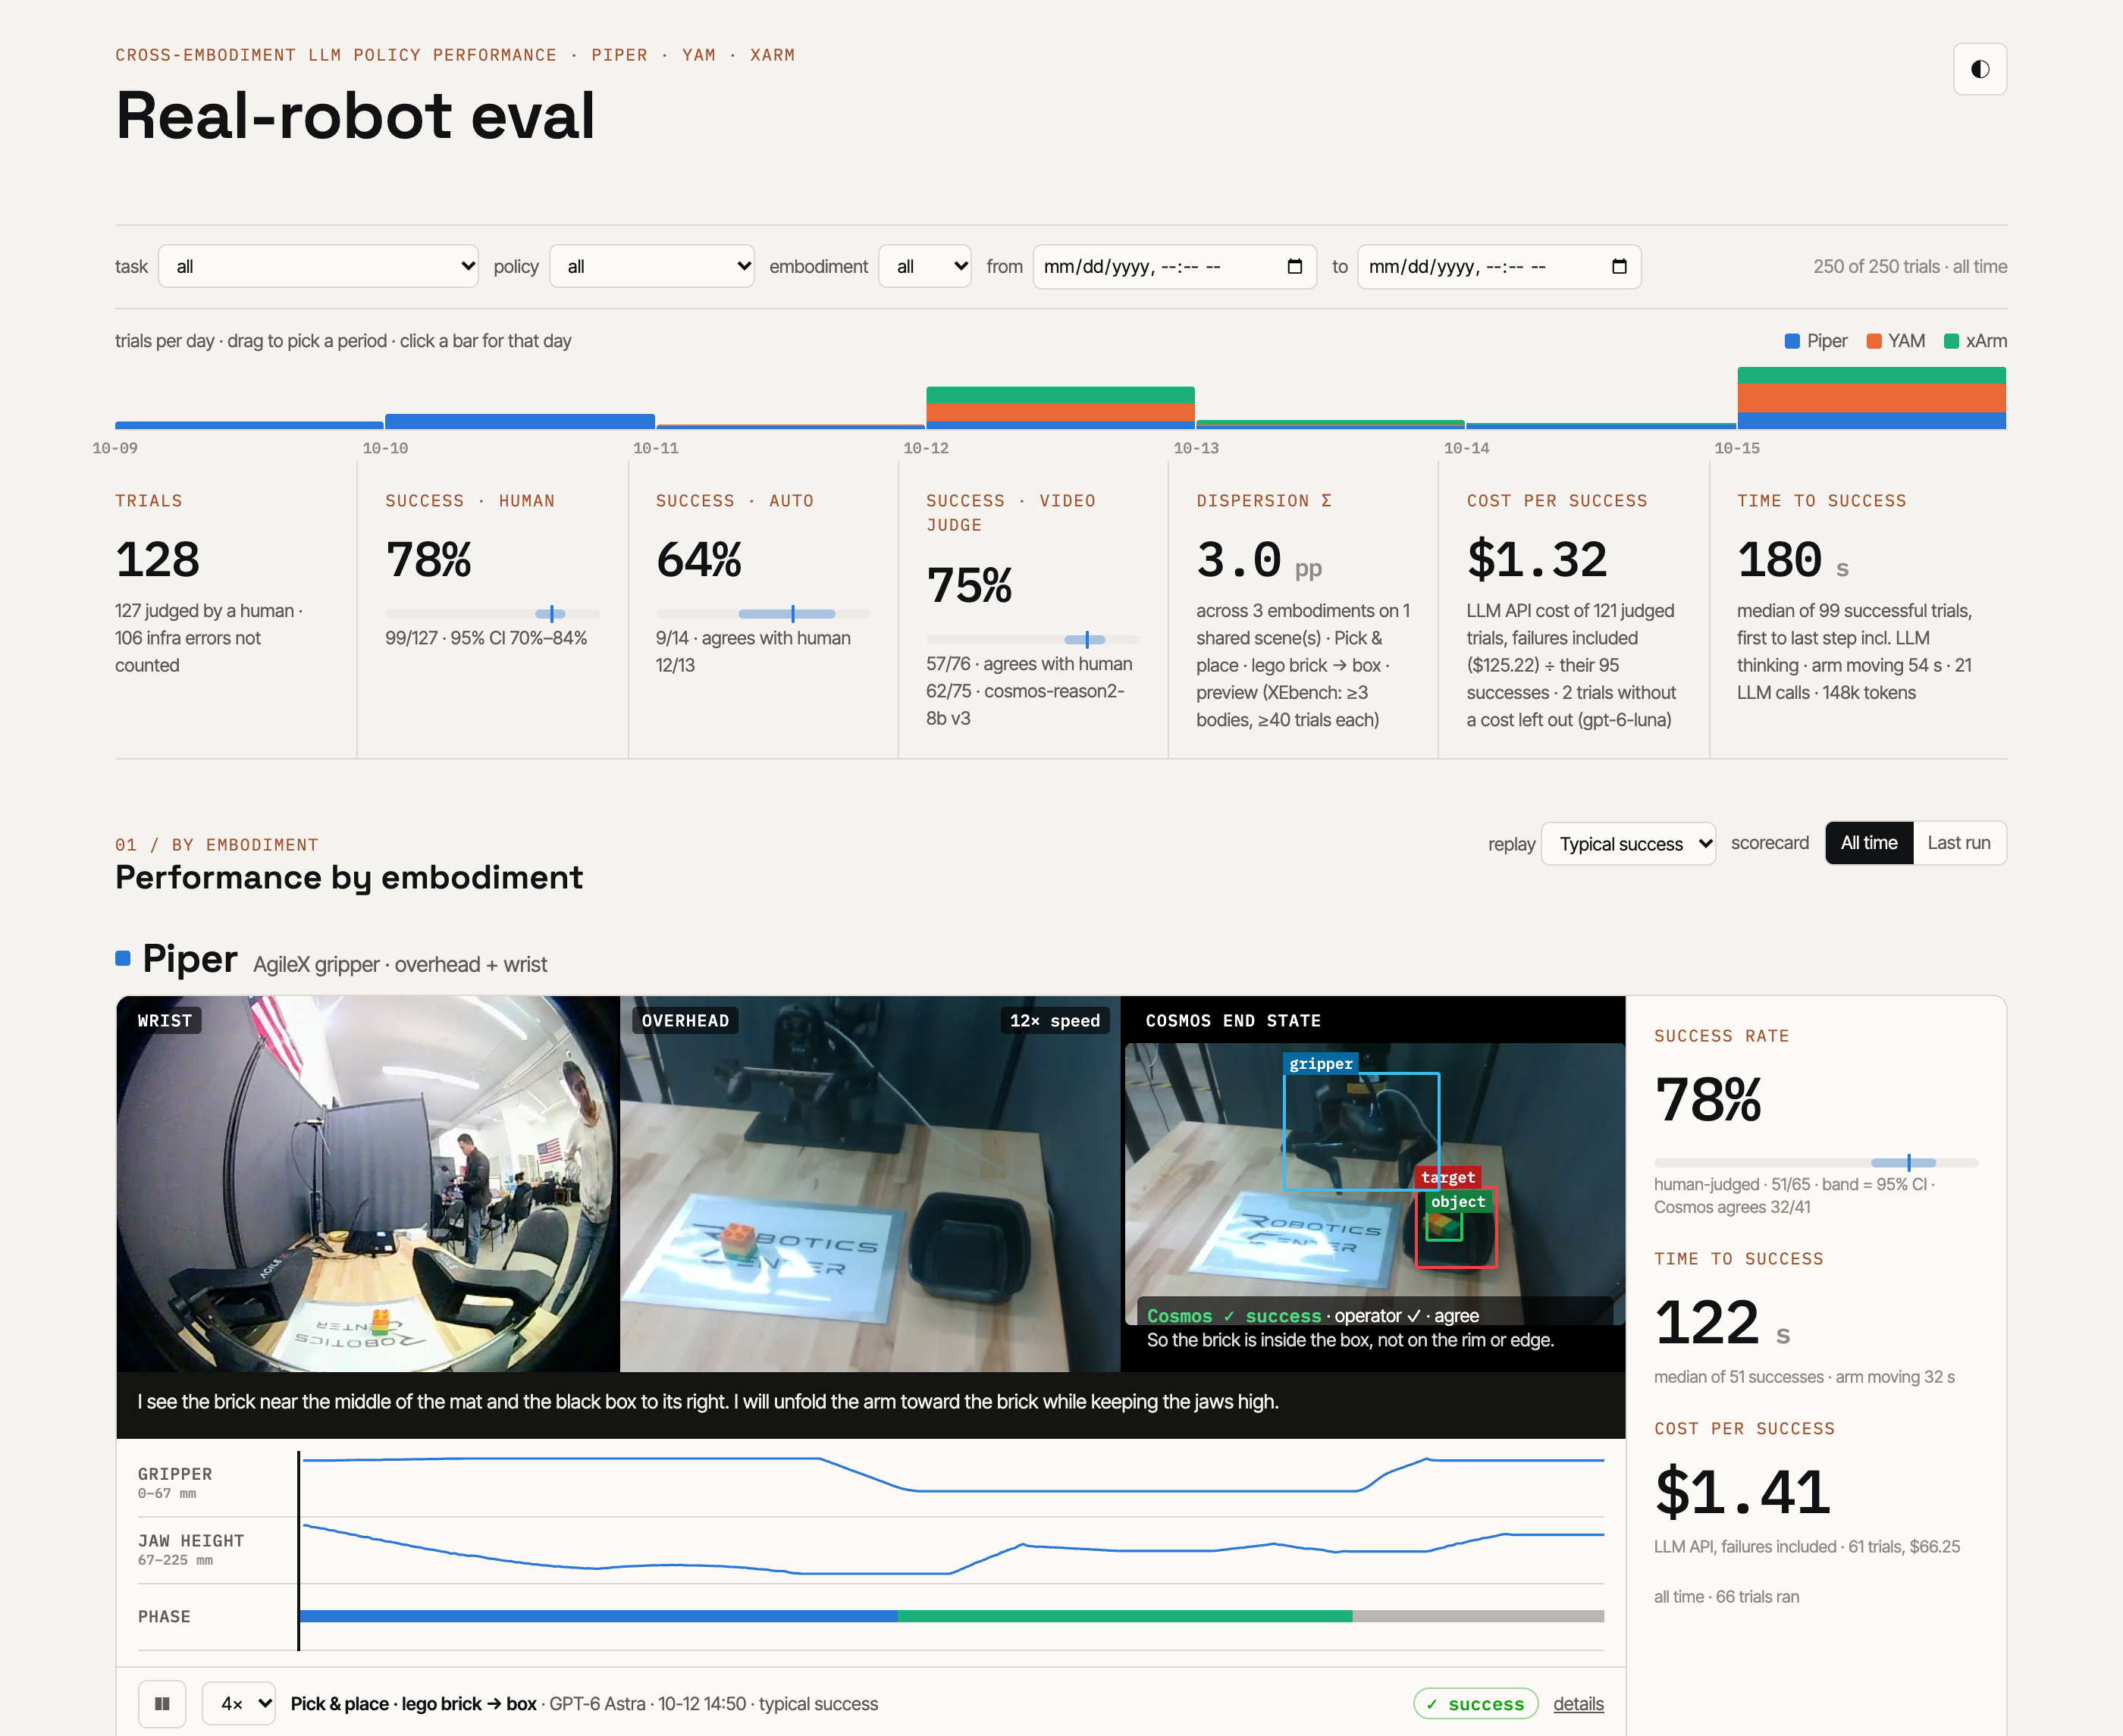
Real-robot eval dashboard.
Every trial, with synced video replay, the operator's verdict and a video-model judge side by side.
Three embodiments, same task.
Put the lego brick in the black box, run by GPT-6 Astra on each arm.
AgileX Piper · AgileX gripper
I²RT YAM · 4310 linear gripper
UFactory xArm · UFactory gripper
How it works.
More to come.
Next for the XEbench harness:
- Dexterous handsMulti-finger hand tasks.
- Two handsBimanual tasks.
- More modelsVLAs (GR00T, π0) and world action models.
- Human baselineTeleoperated runs on the same robots.
- Sharper auto-judgeFailure modes and event timing from video.
Preliminary pilot data, not official Robotics Center or XEbench results. Robots, footage and data © Robotics Center. Model and robot names are trademarks of their owners.